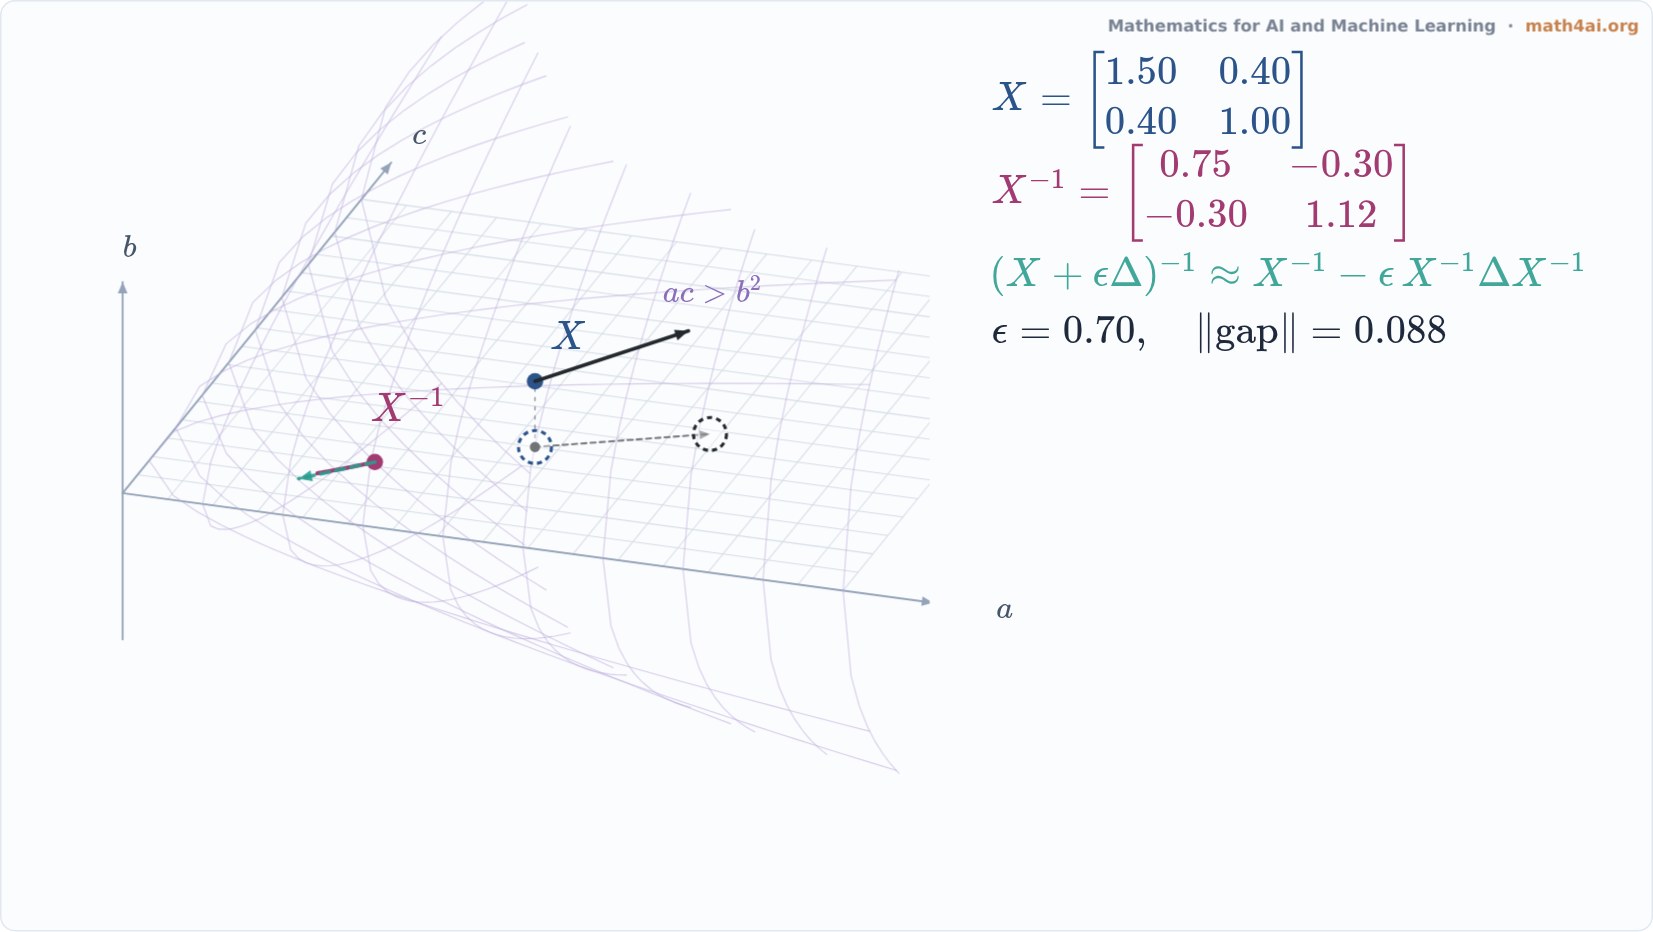
The Derivative of the Matrix Inverse
An interactive live film: 2 x 2 symmetric matrices as points in 3D, the cone of positive definite ones, and the Frechet derivative of the inverse as a straight-line prediction whose error falls like epsilon squared.
Narration
Every two by two symmetric matrix is a point in space: its two diagonal entries along the floor, and its off diagonal entry going up. The positive definite matrices fill this cone.
Here is a matrix X inside the cone, and its inverse, another point in the same cone.
The rest of the narration is in the book's Companion.
More from Chapter 11
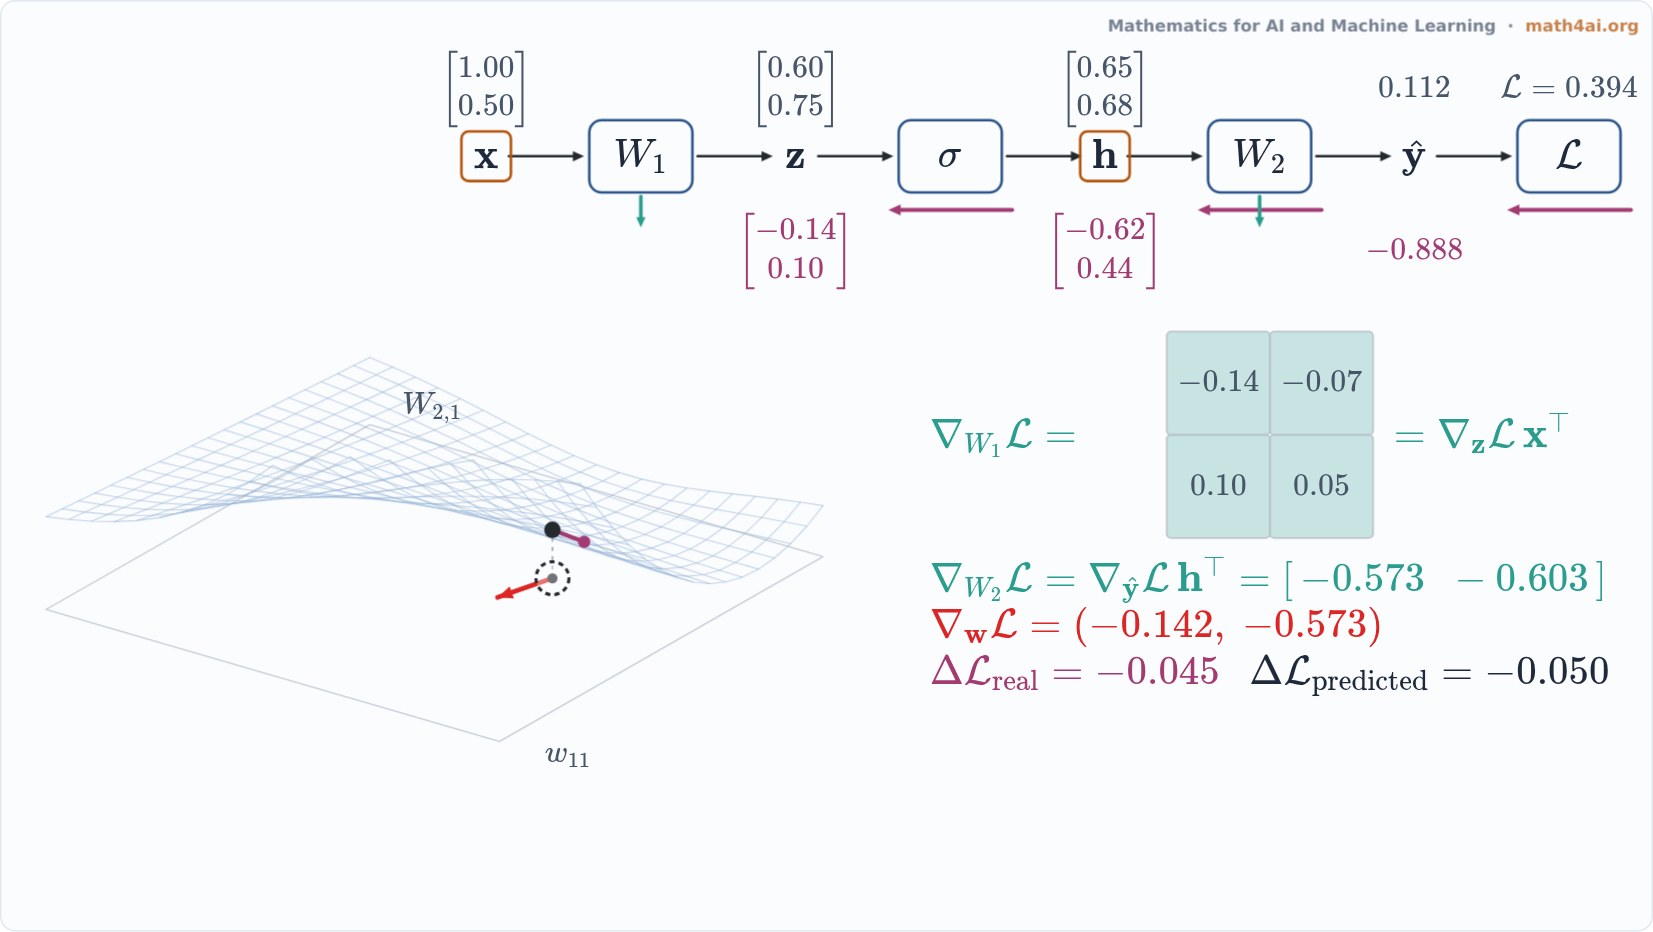 Interactive1:54Backpropagation, One VJP per LayerChapter 11
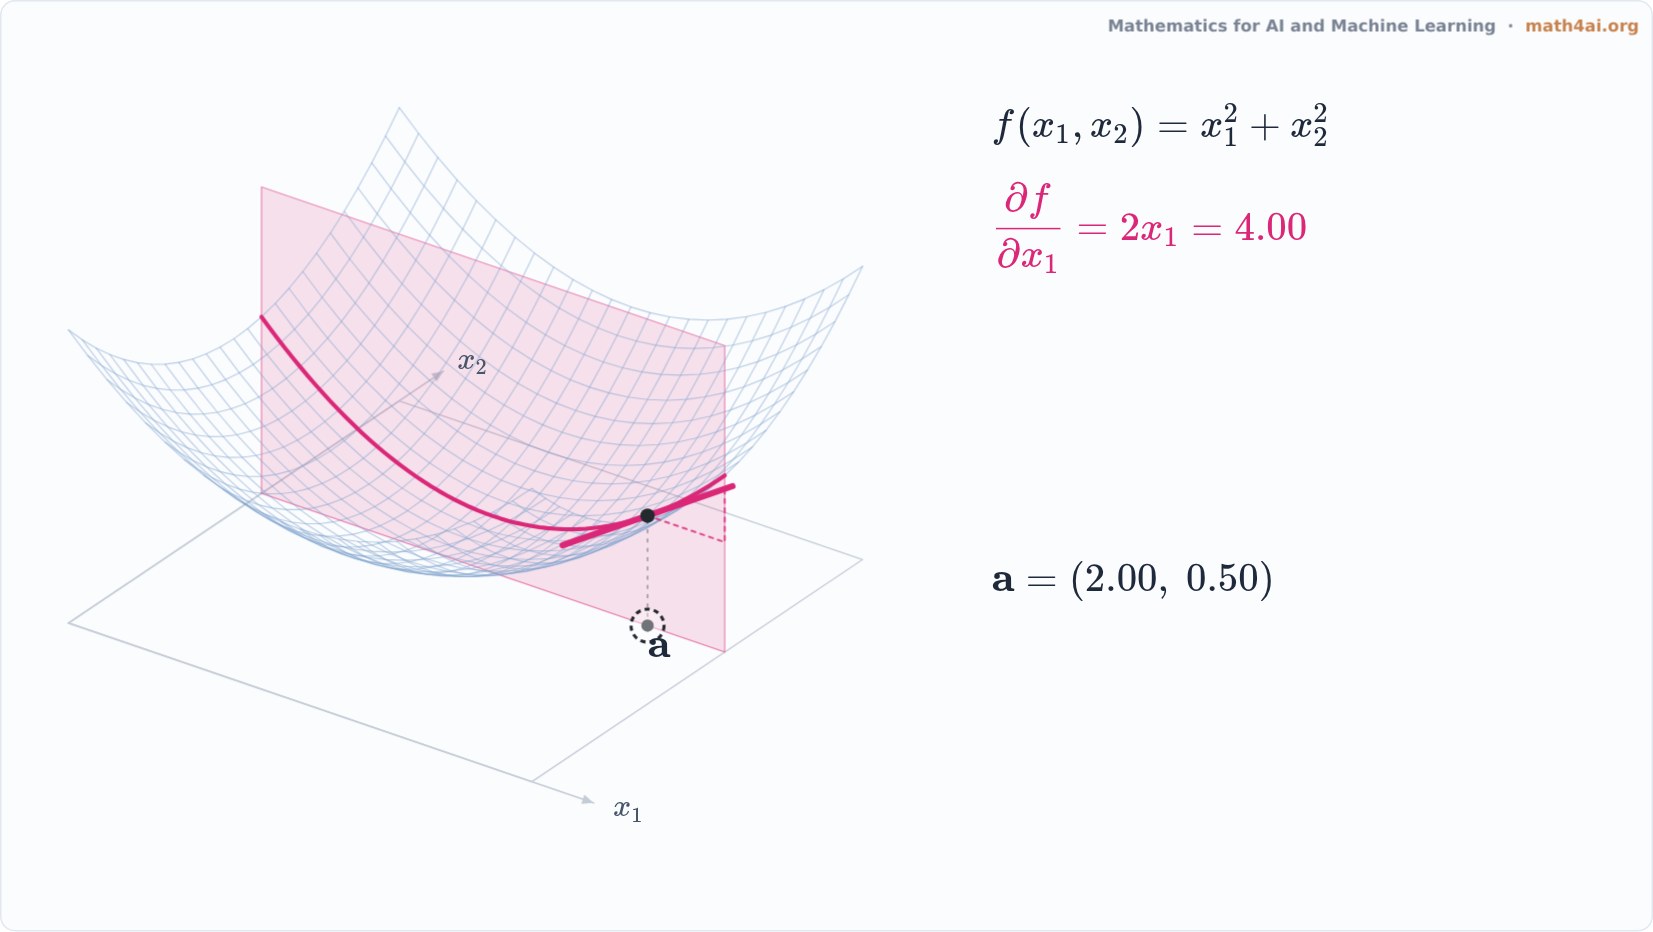 Preview1:27Partial Derivatives Are Two SlicesChapter 11
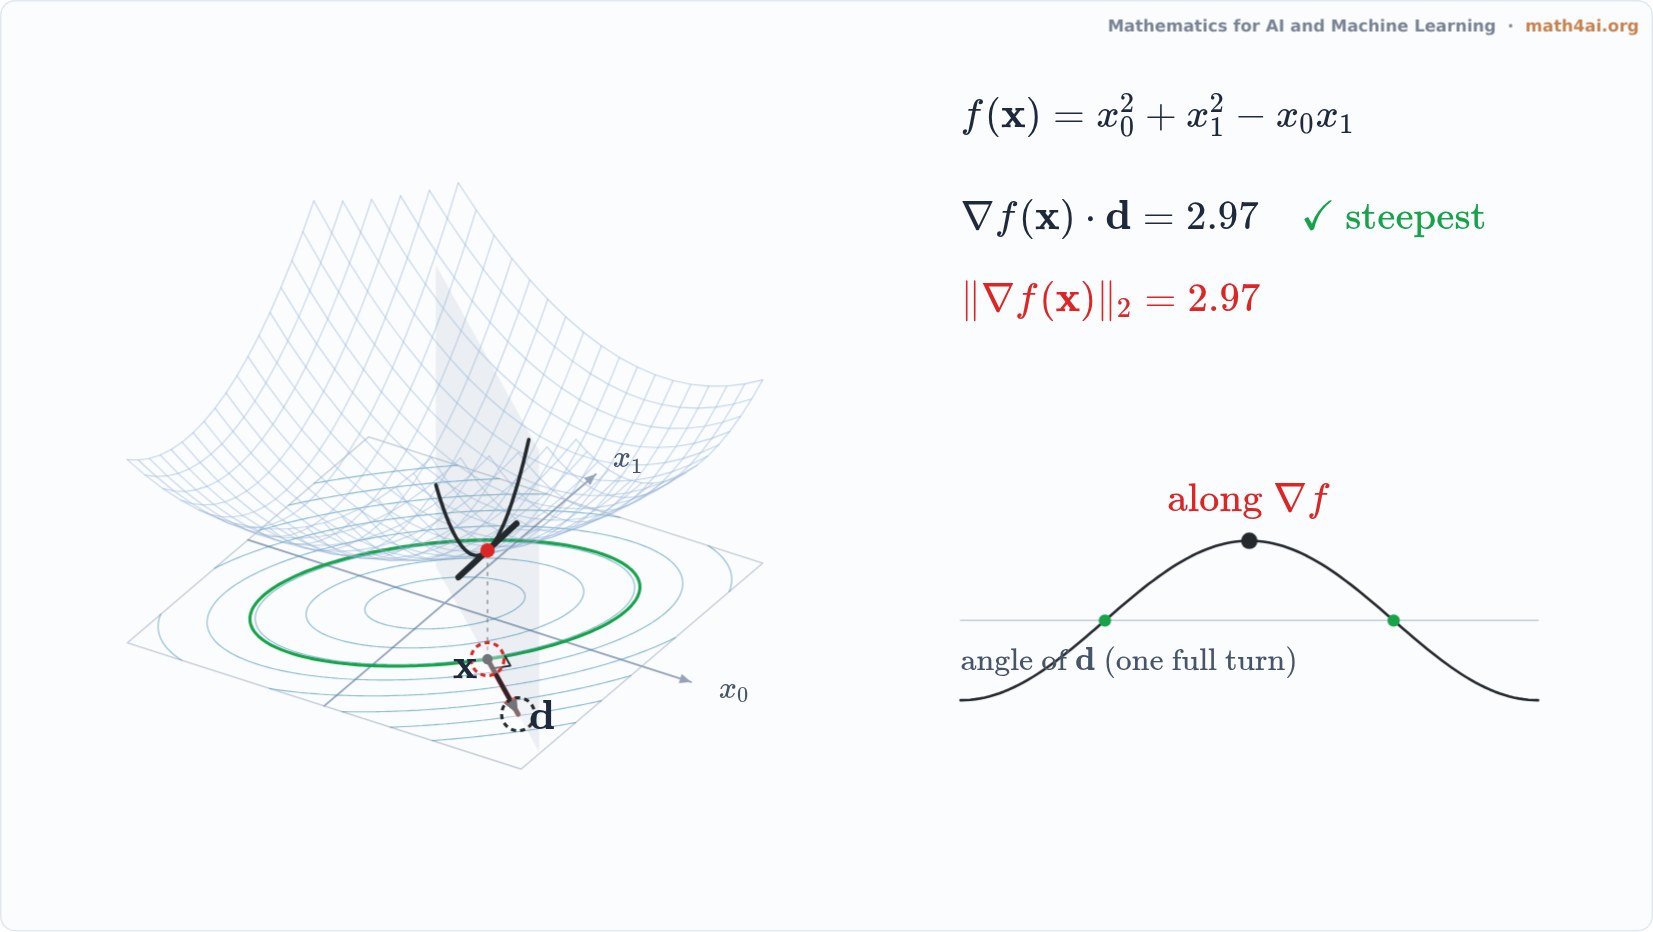 Preview1:34The Gradient Is the Steepest DirectionChapter 11
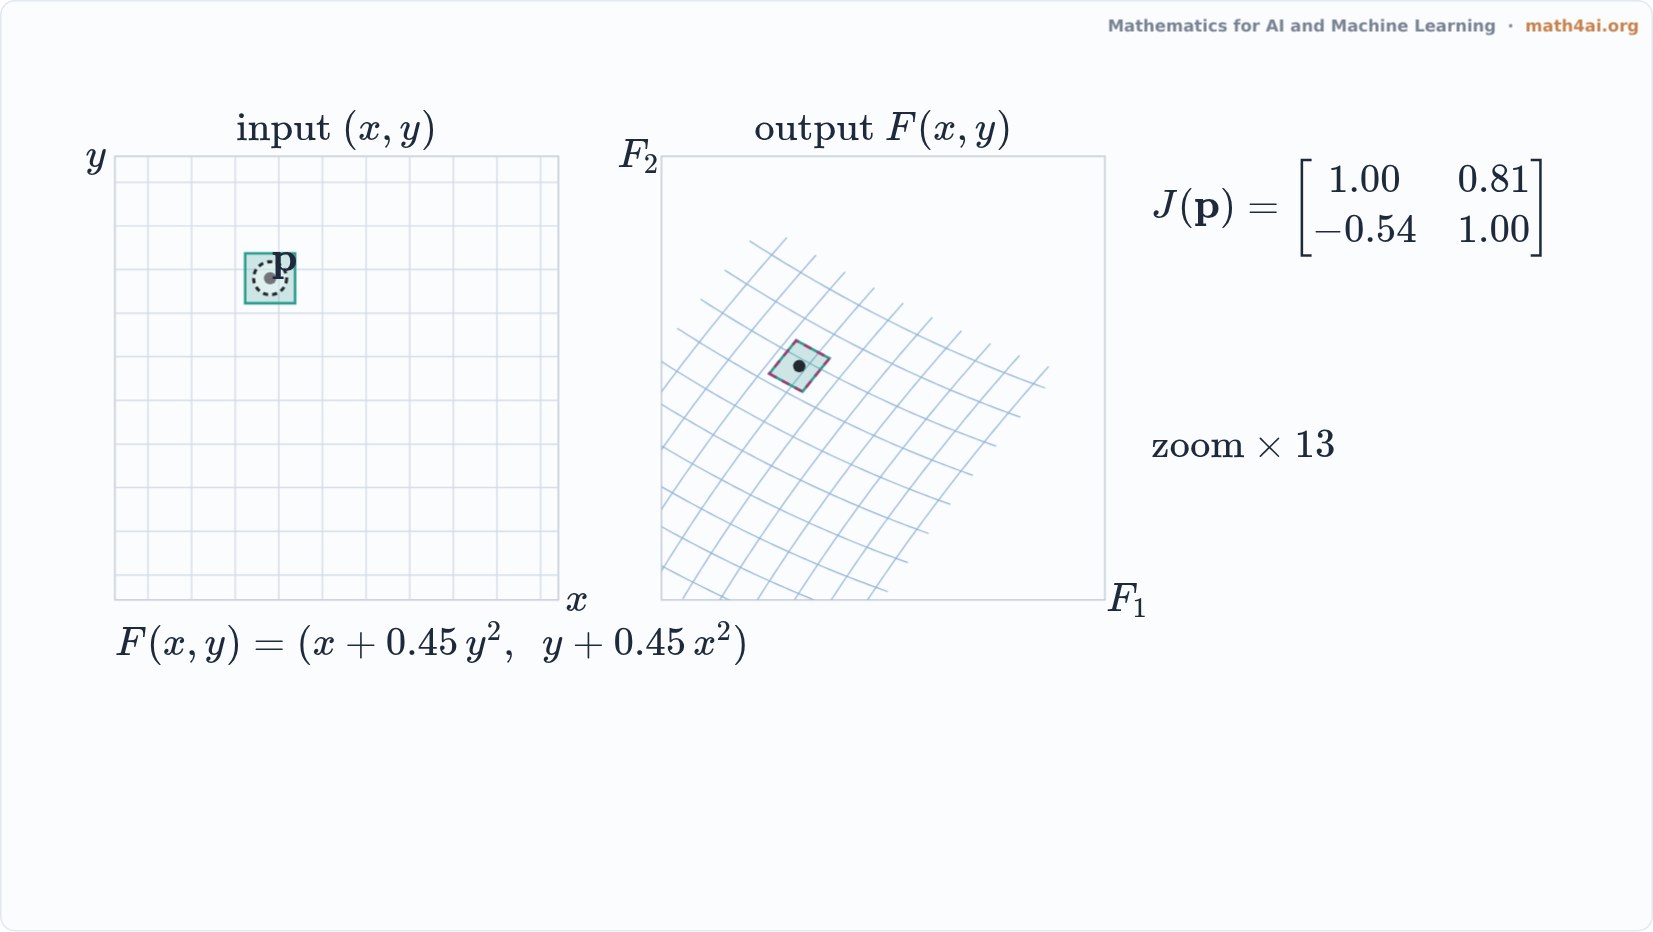 Preview1:42Jacobian Matrix: Linearizing a MapChapter 11
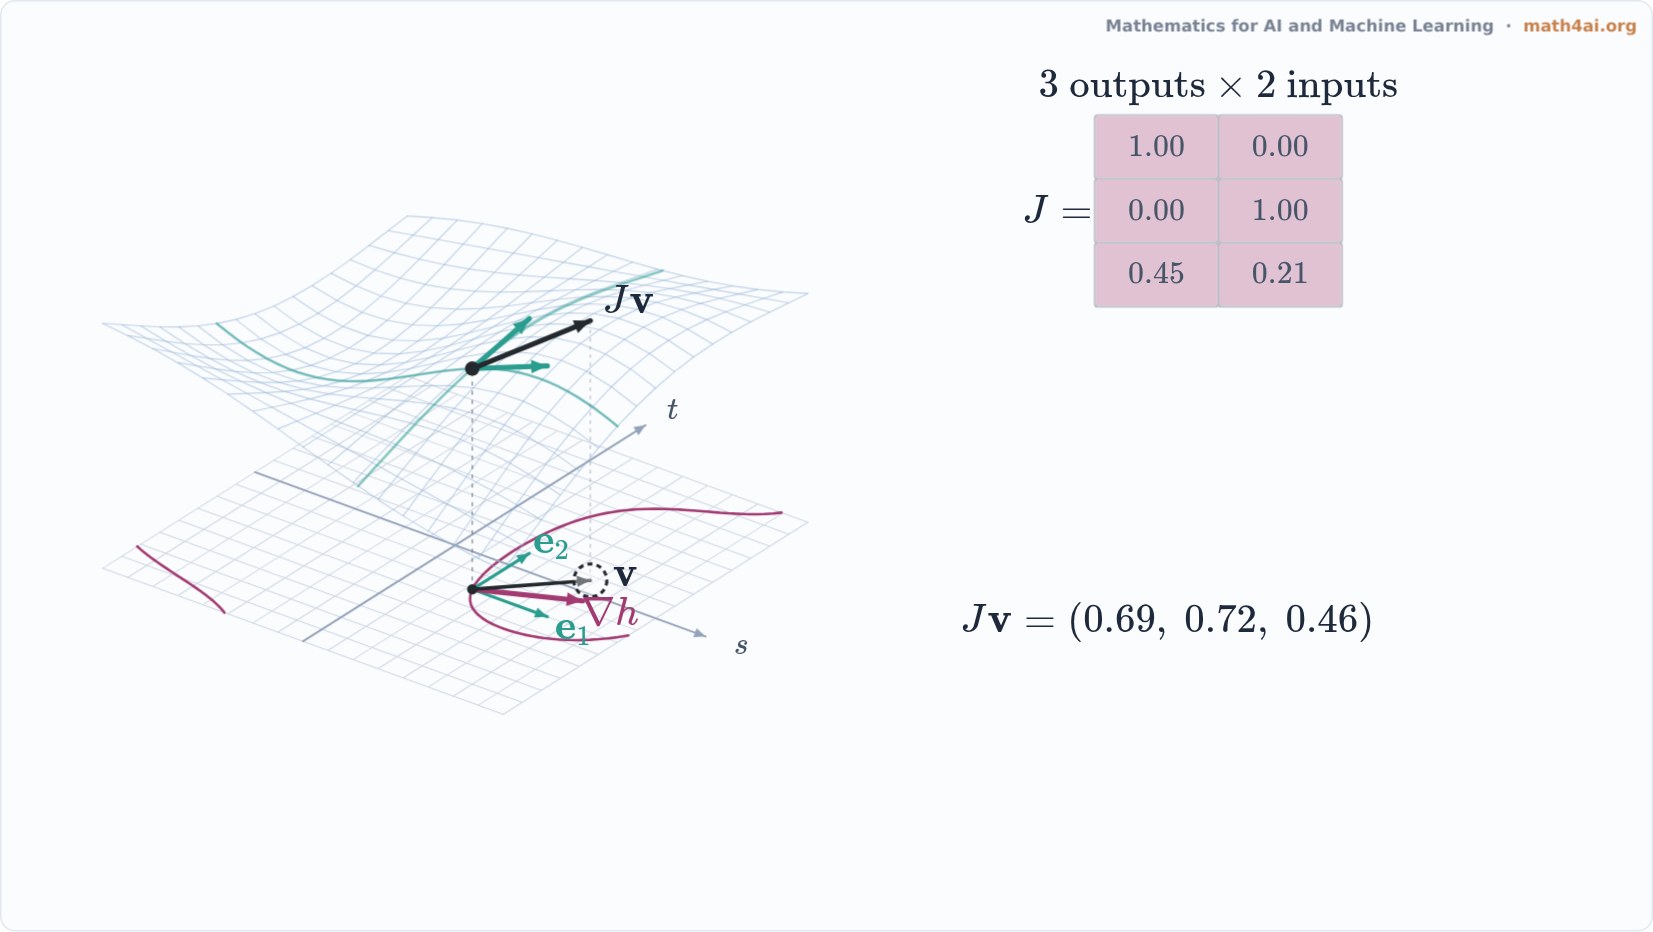 Preview1:54Forward or Reverse: Filling the JacobianChapter 11
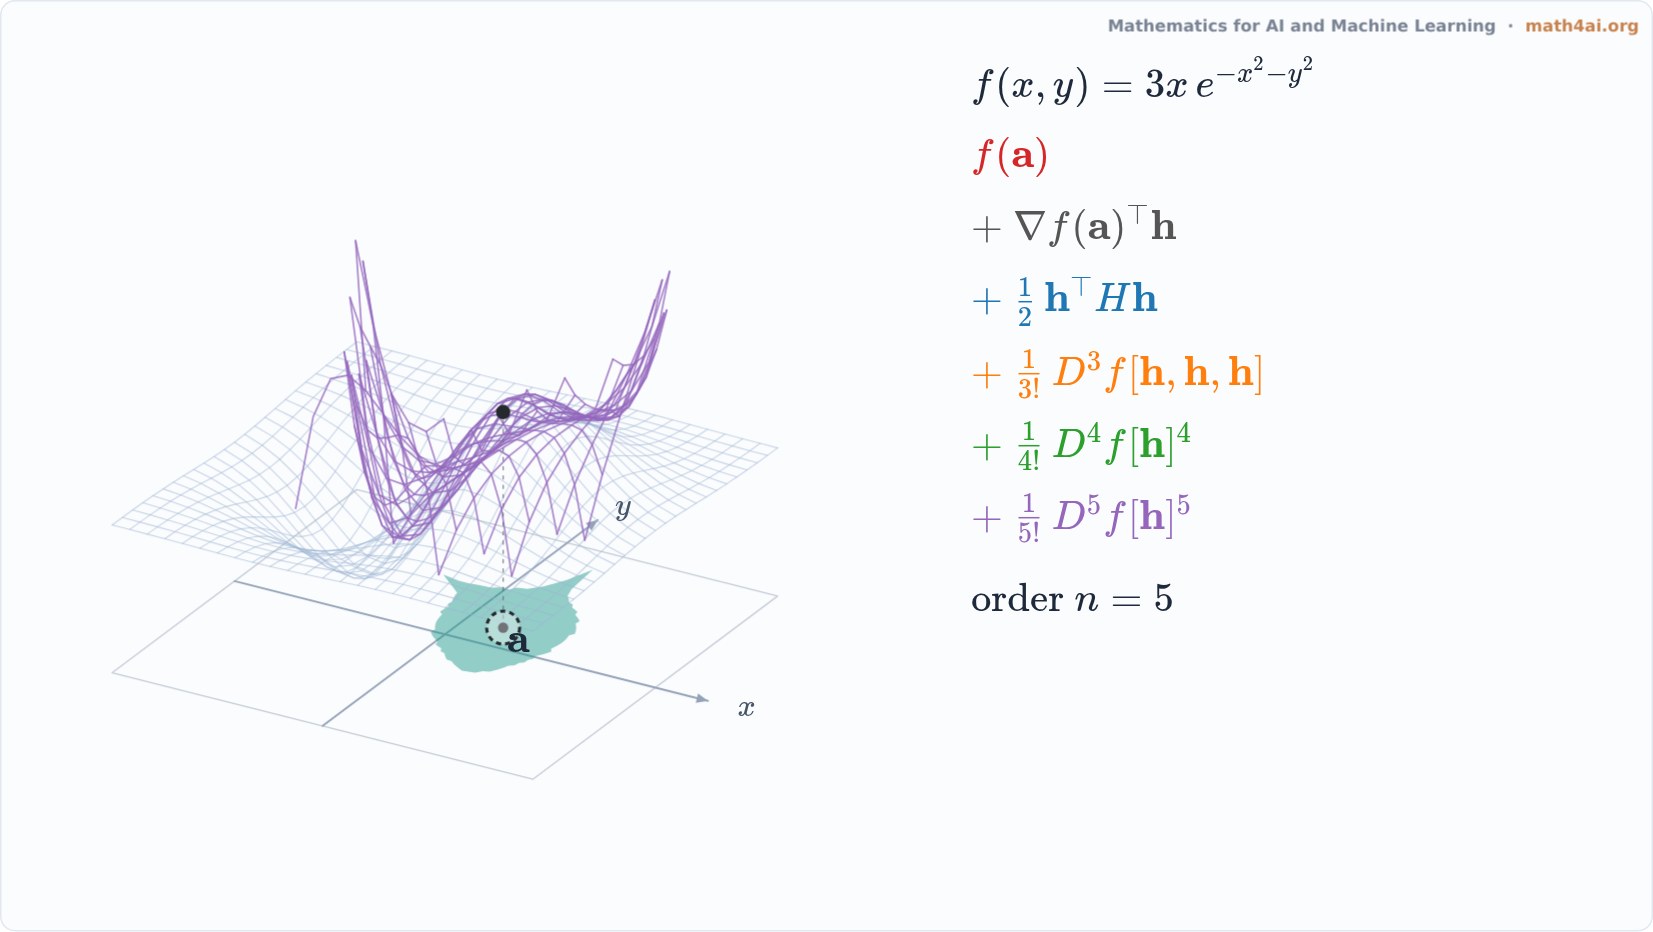 Preview1:32Taylor Expansion, One Term at a TimeChapter 11
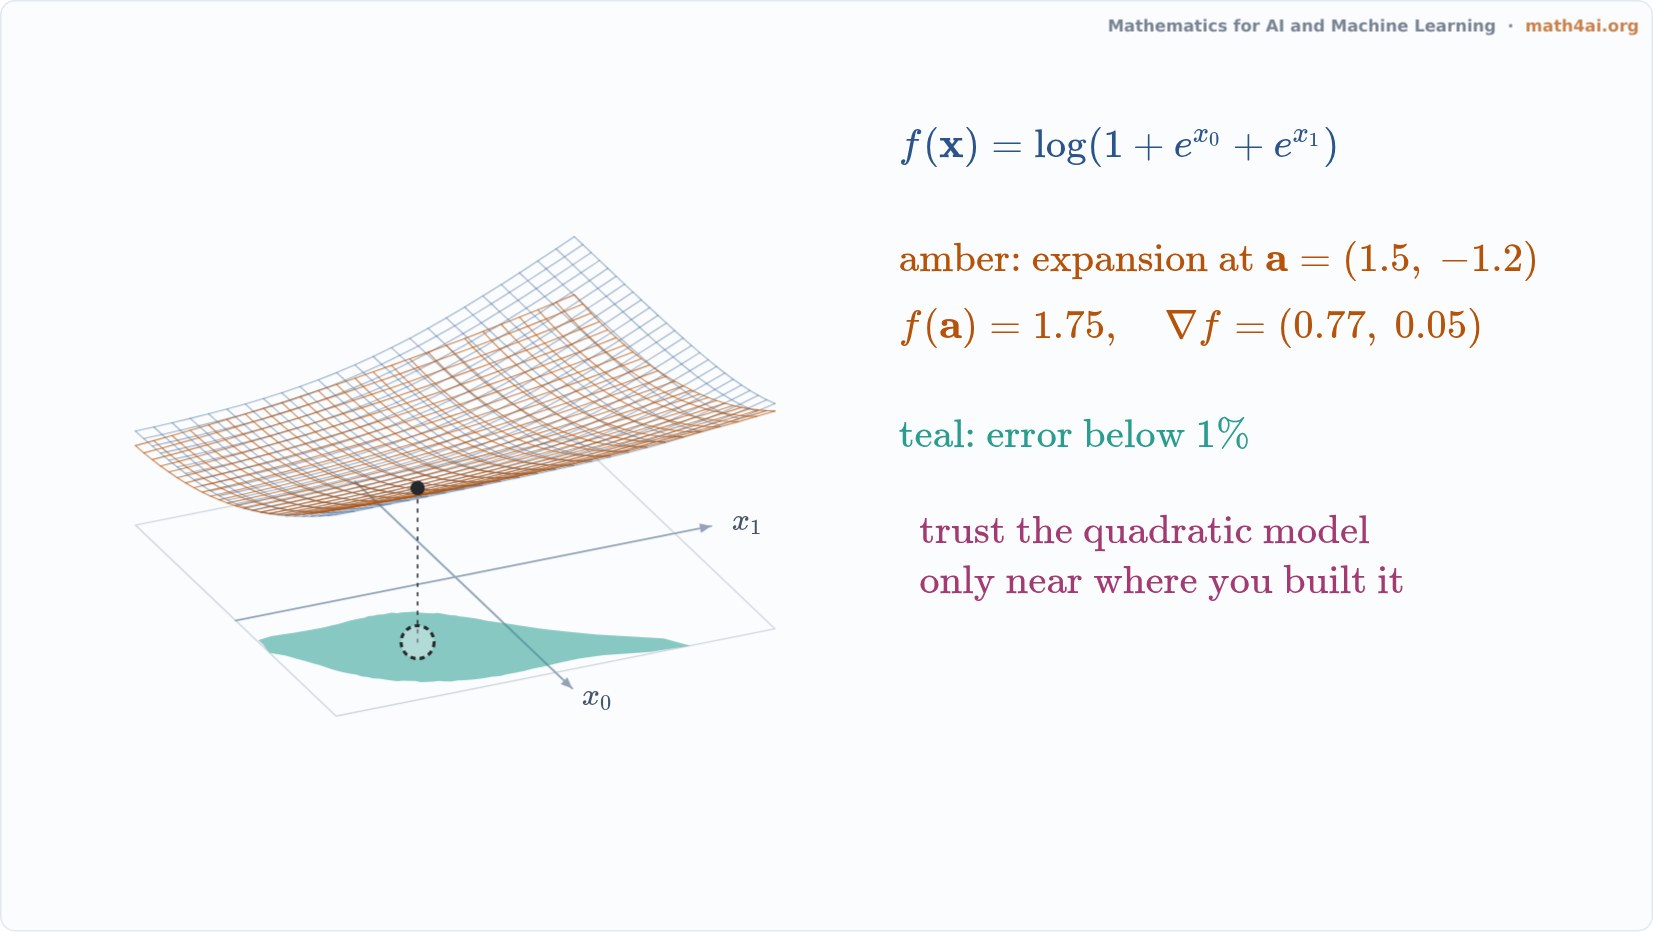 Preview1:30Second-Order Taylor: Where the Quadratic Model Can Be TrustedChapter 11
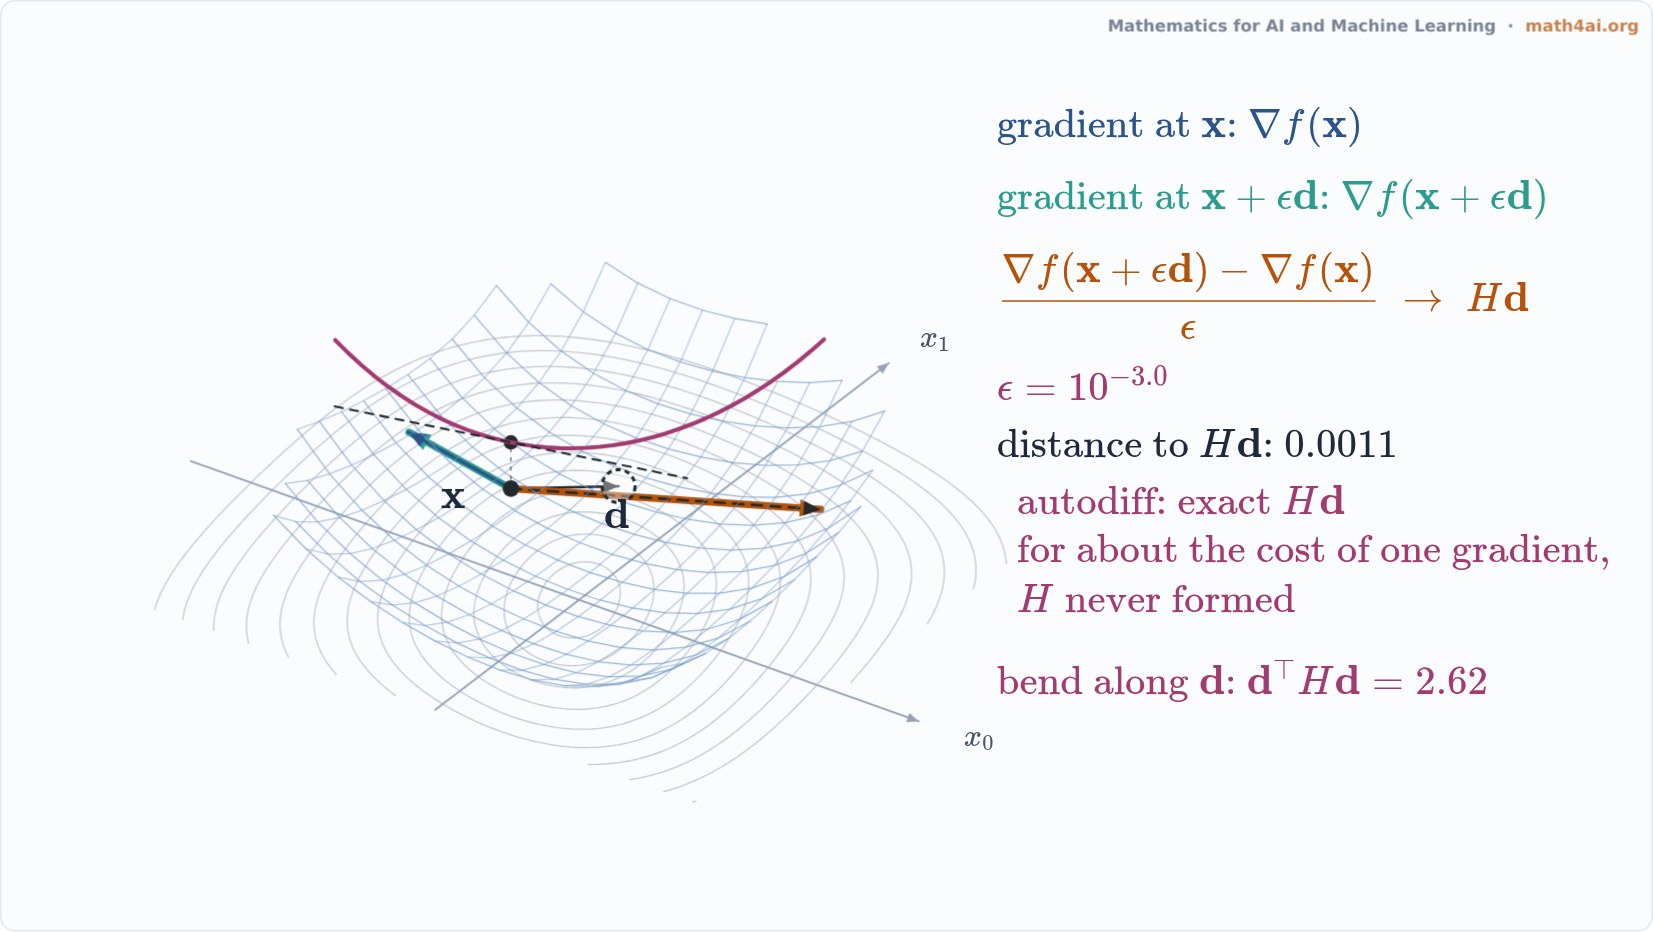 Preview1:38A Hessian-Vector Product from Two GradientsChapter 11
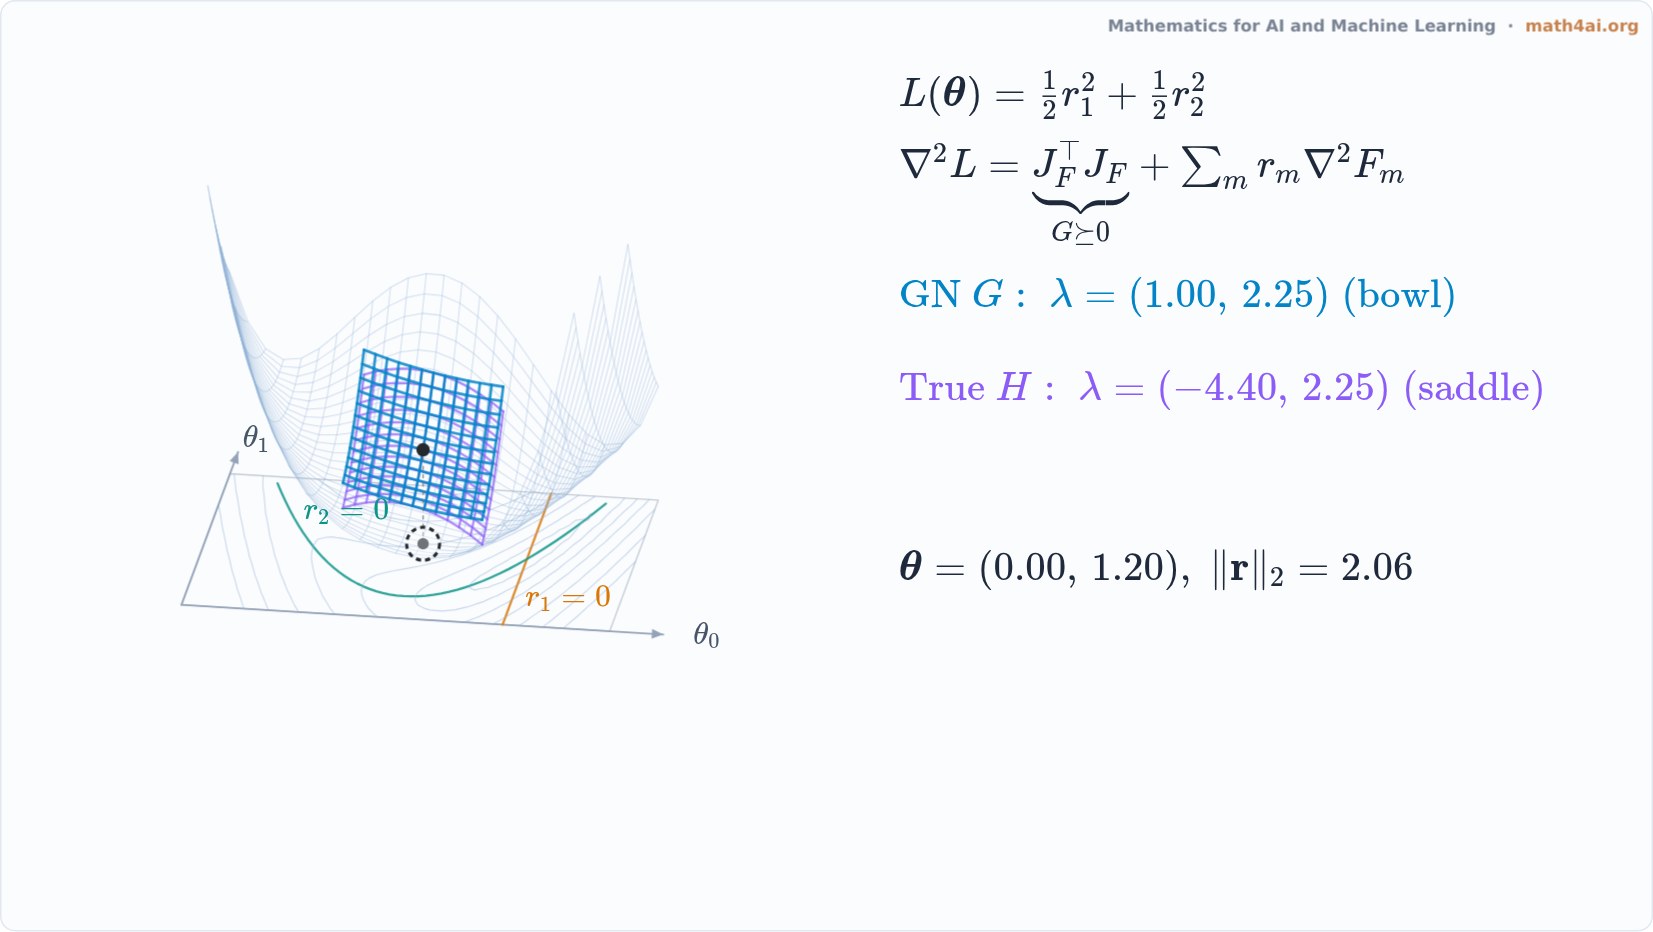 Preview1:34The Gauss–Newton MatrixChapter 11
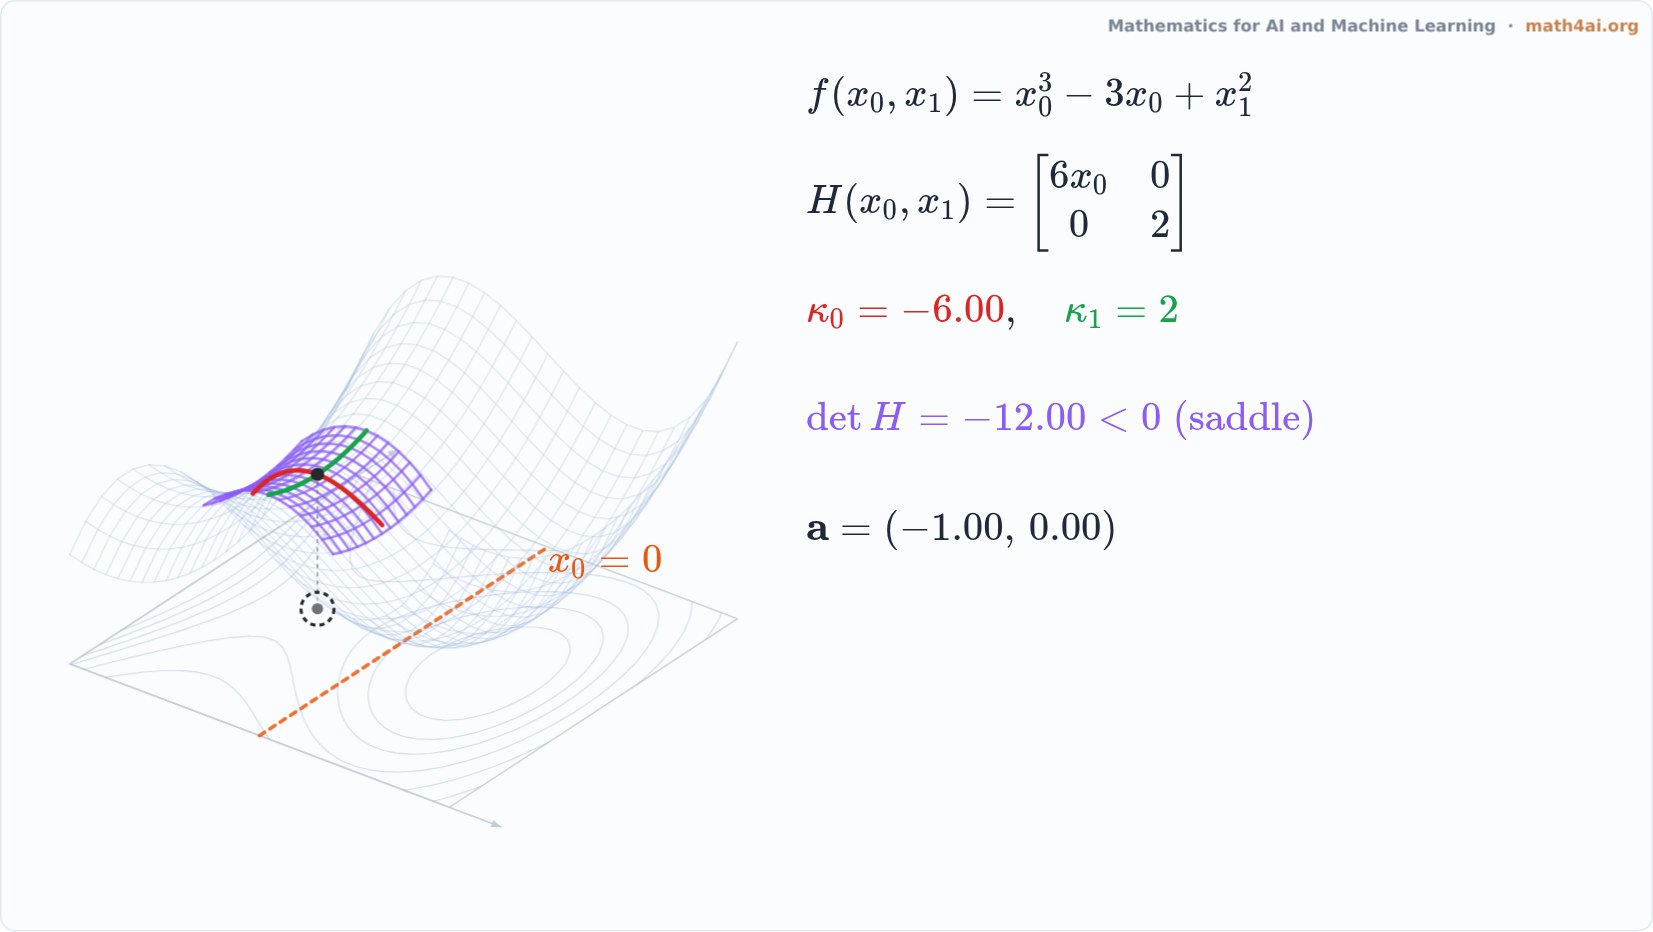 Preview1:44Hessian Matrix: Bowls, Saddles and Curvature DirectionsChapter 11
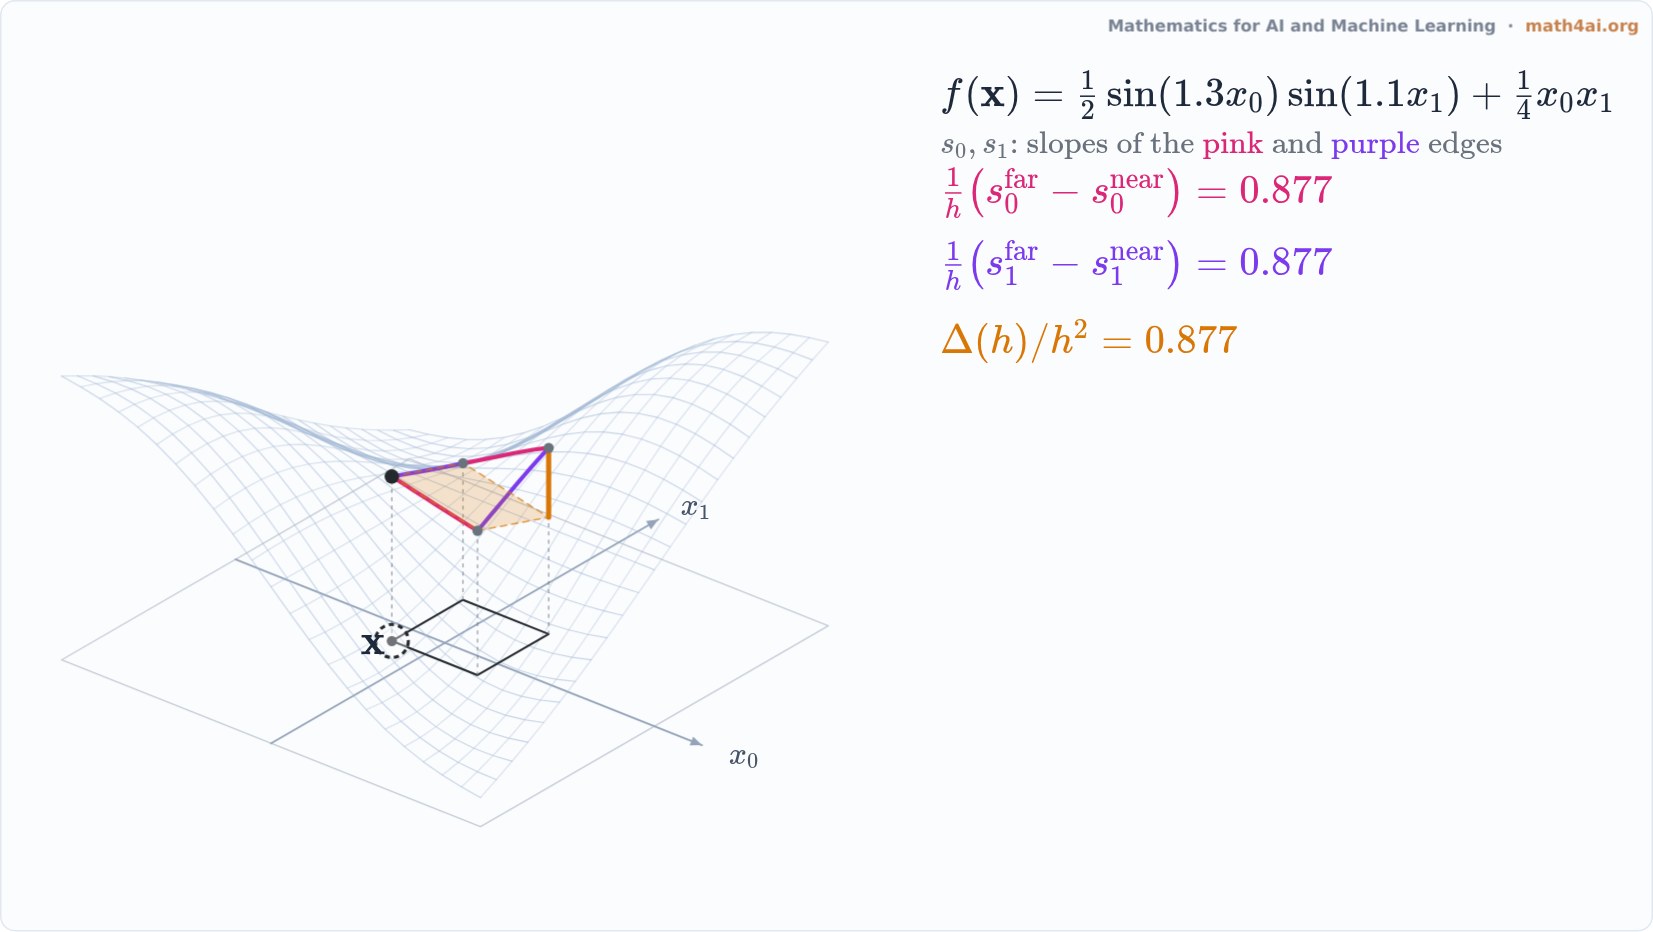 Preview1:37Why the Hessian Is SymmetricChapter 11
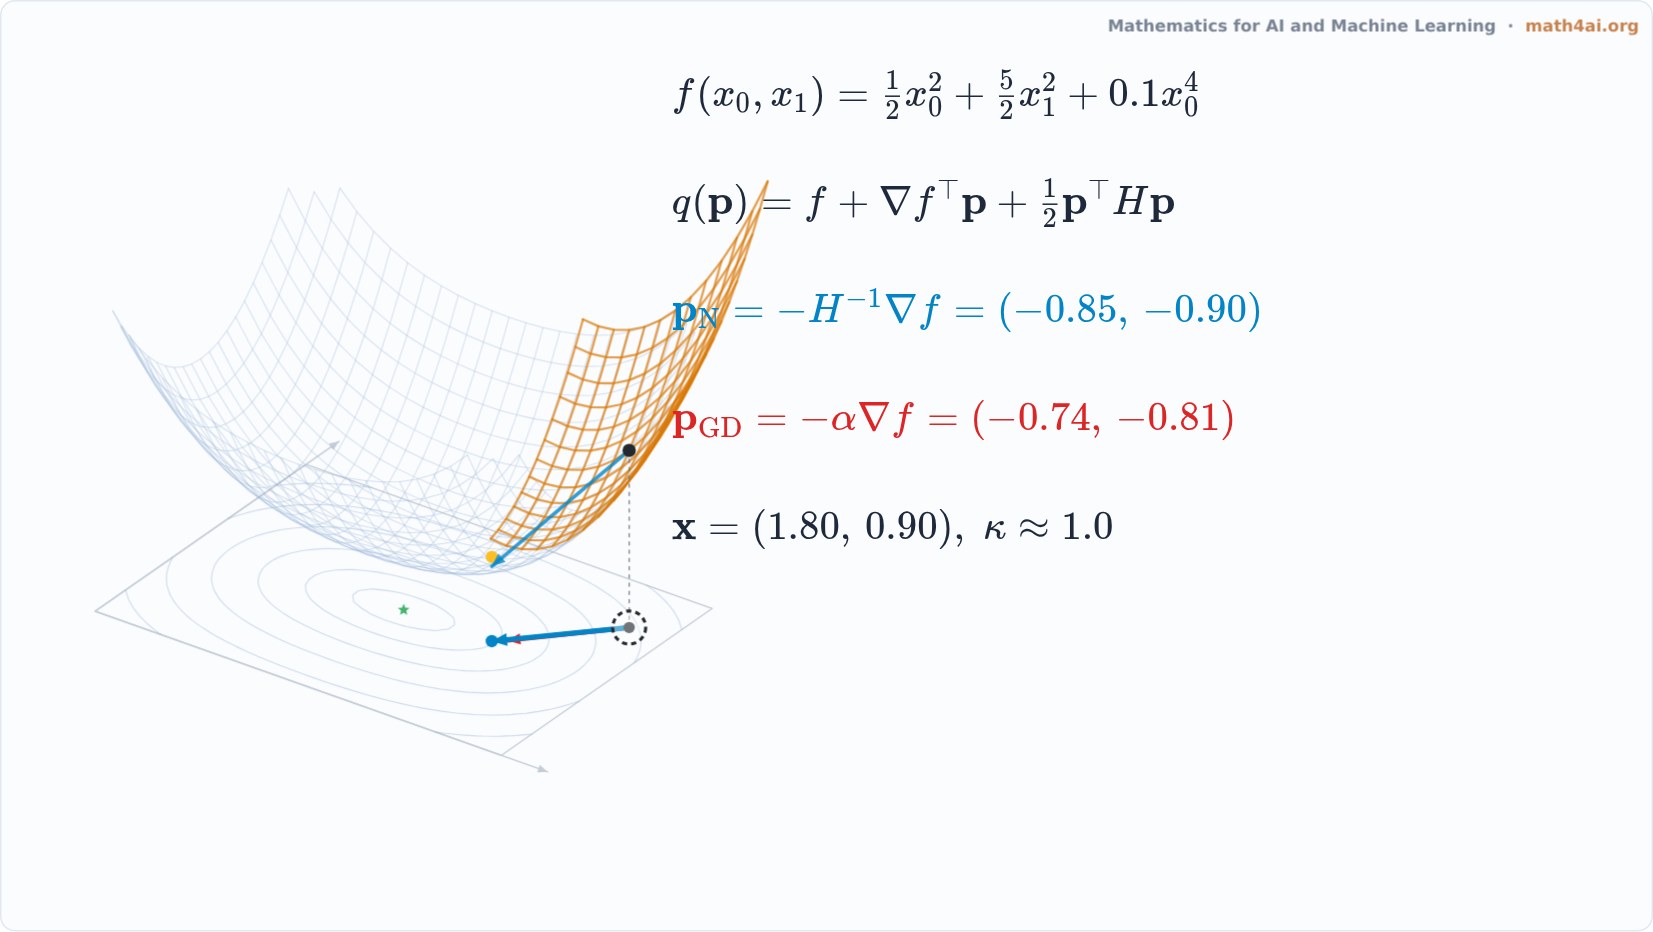 Preview1:26The Newton Step: Jumping to the Taylor Bowl's BottomChapter 11
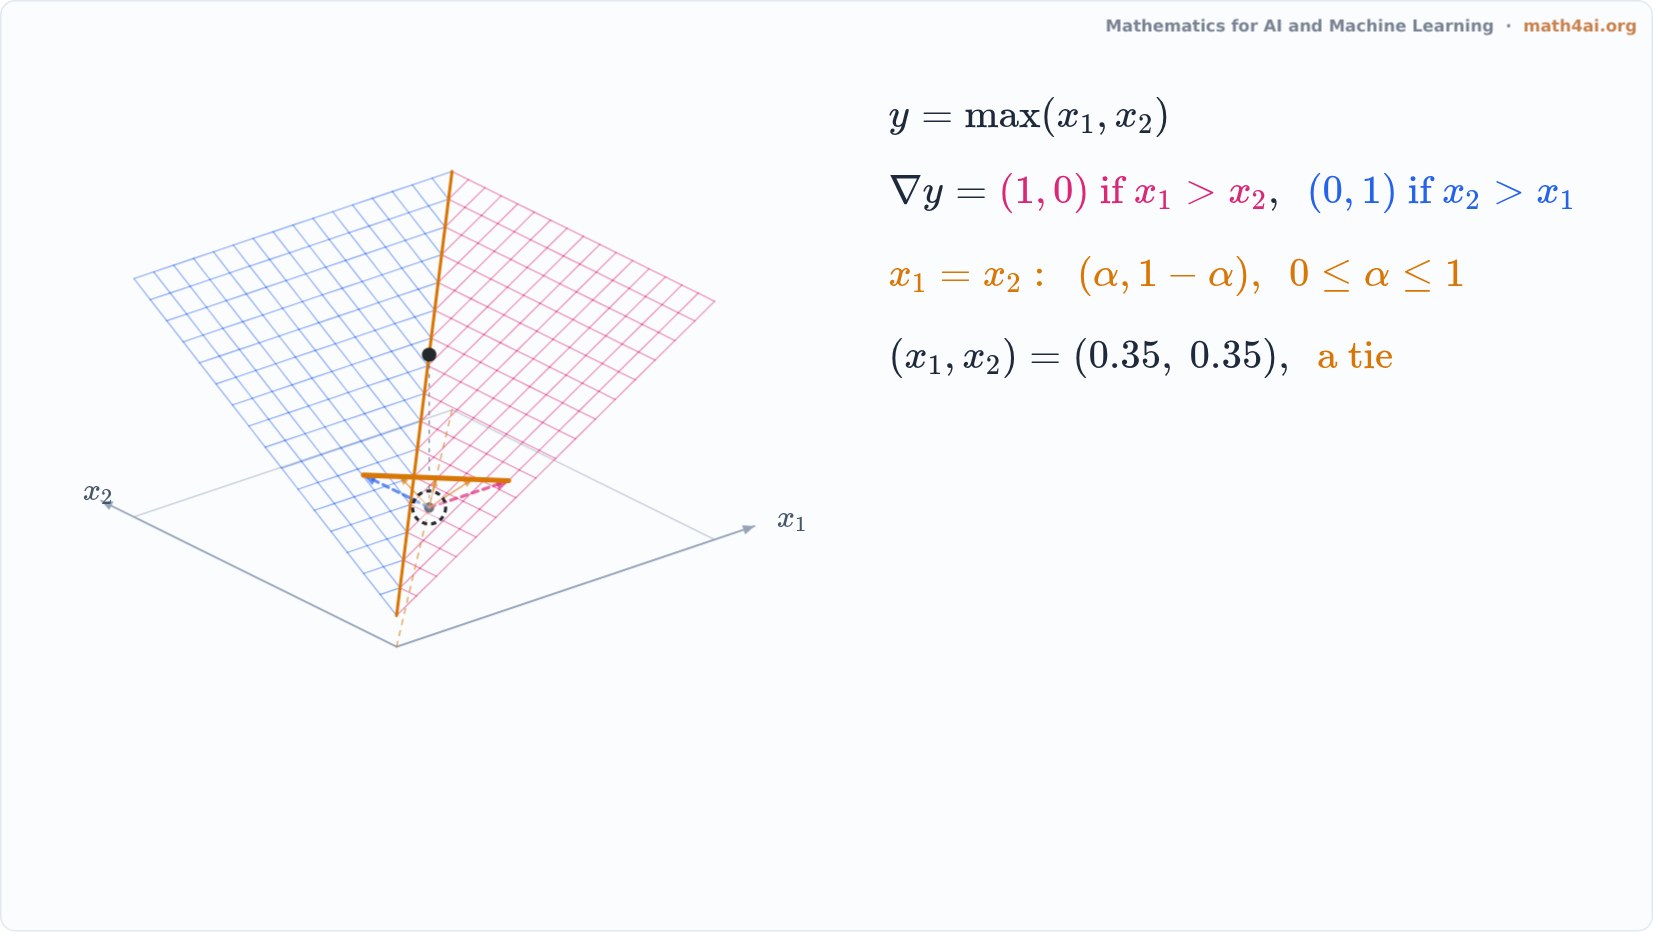 Preview2:36Corners, Maxima and Steps in the Chain RuleChapter 11
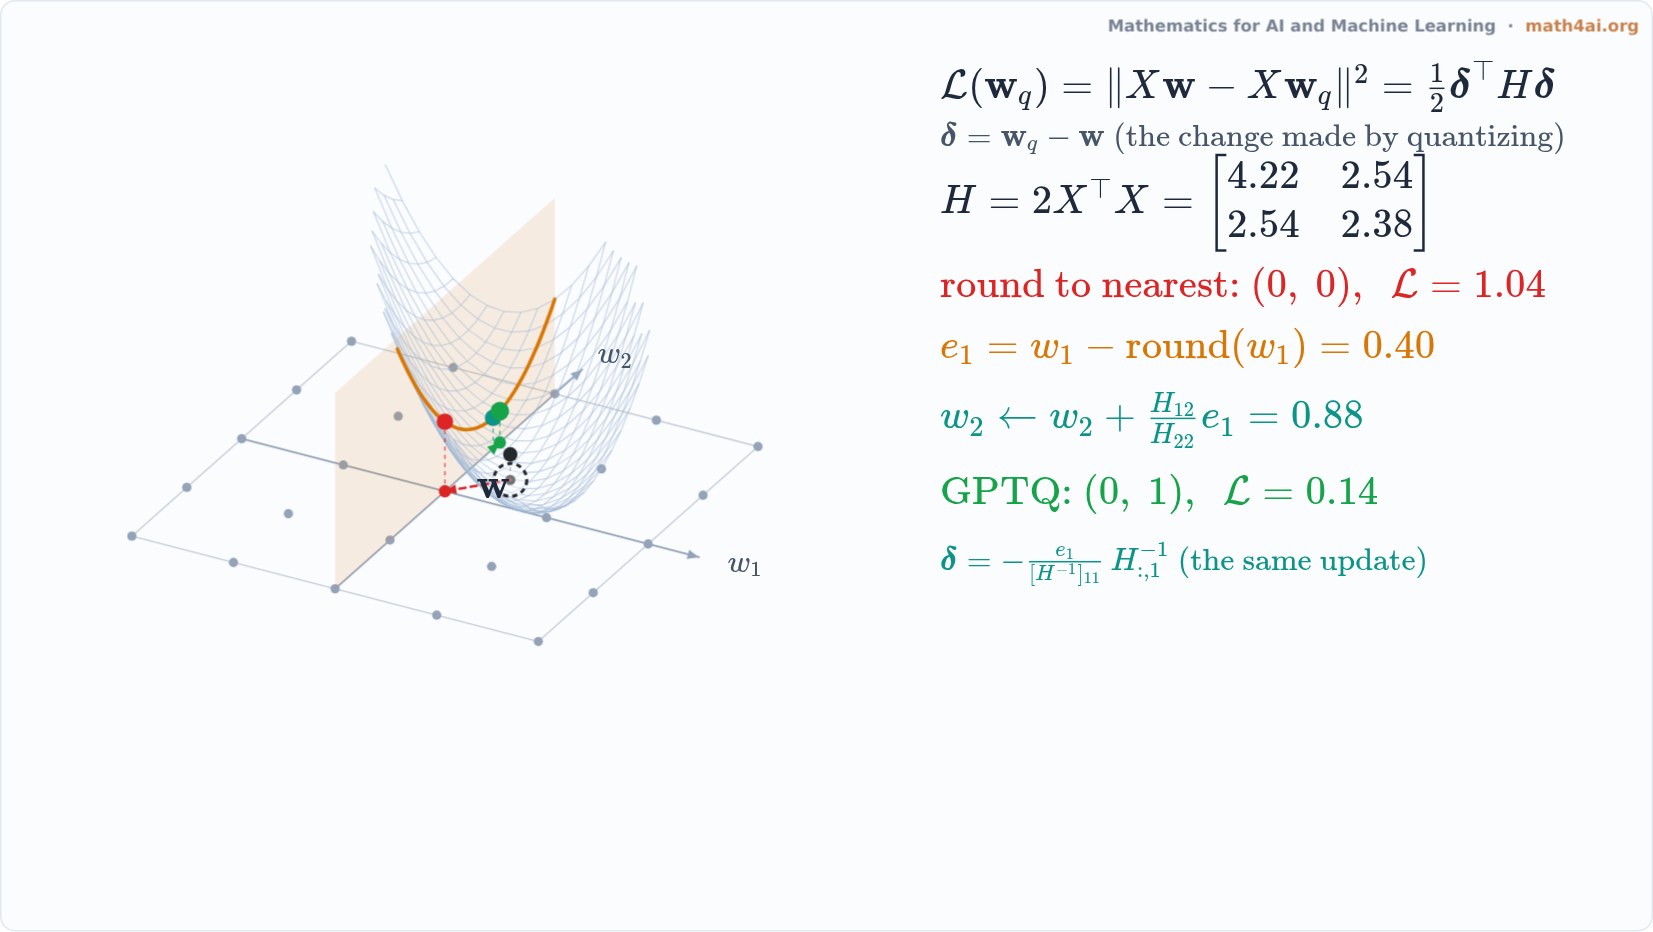 Preview1:59GPTQ: Rounding with the HessianChapter 11
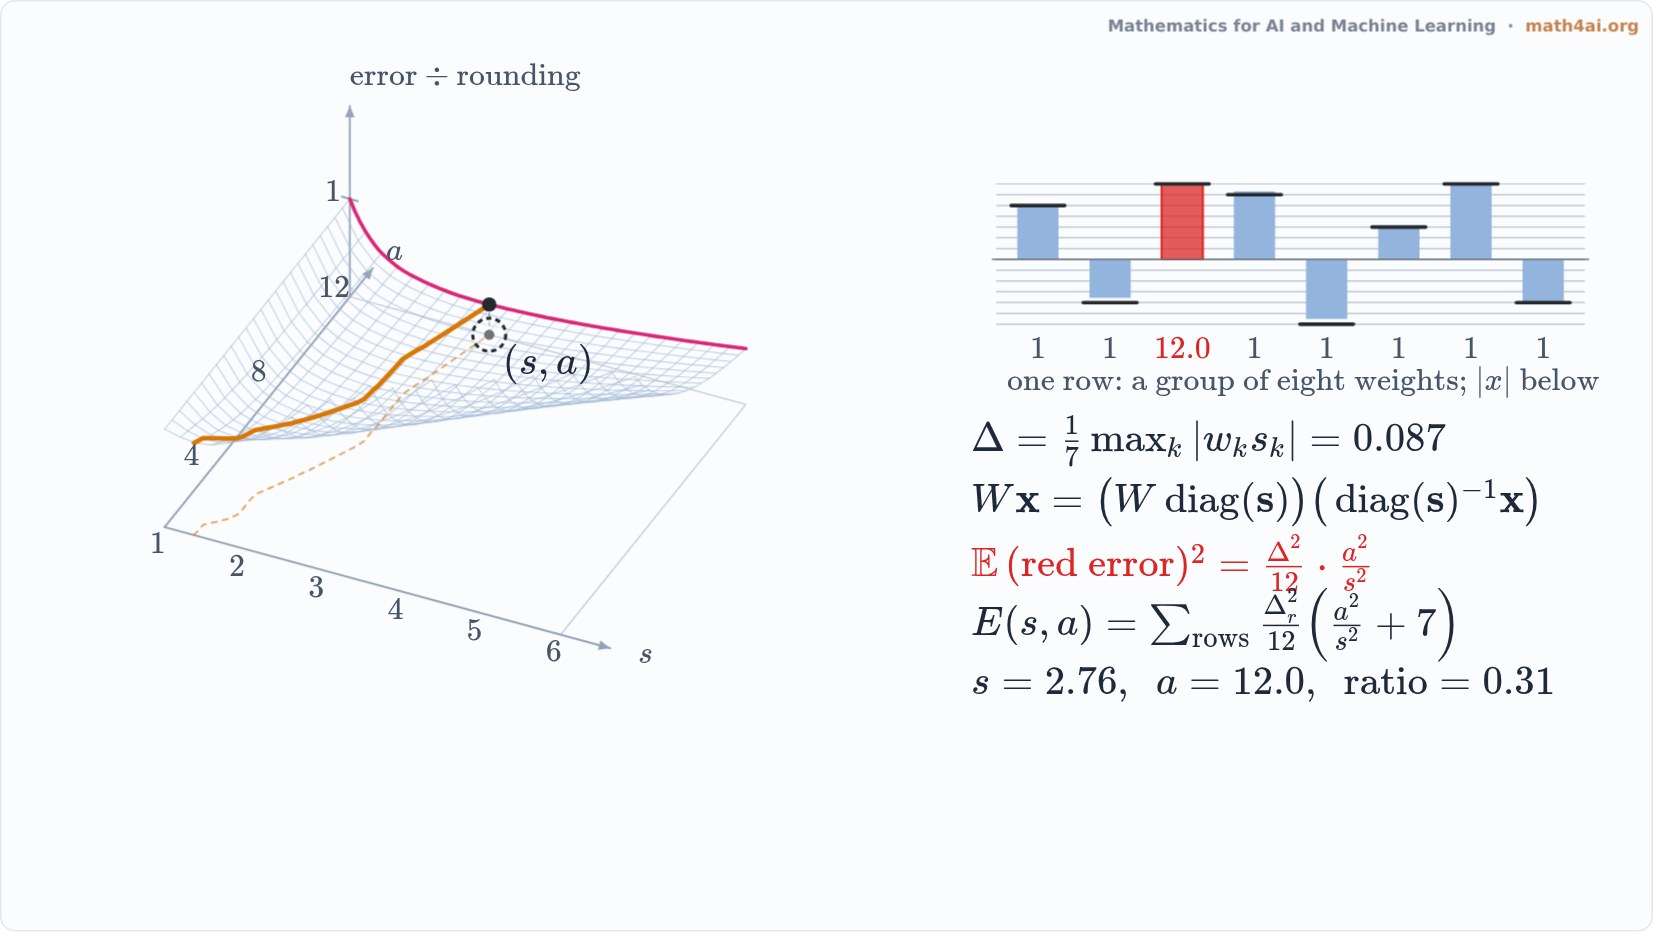 Preview2:12AWQ: Activation-Aware Weight QuantizationChapter 11
 Preview1:41The Implicit Function TheoremChapter 11